

Precision CNC Machining for Robot Wrist Housings
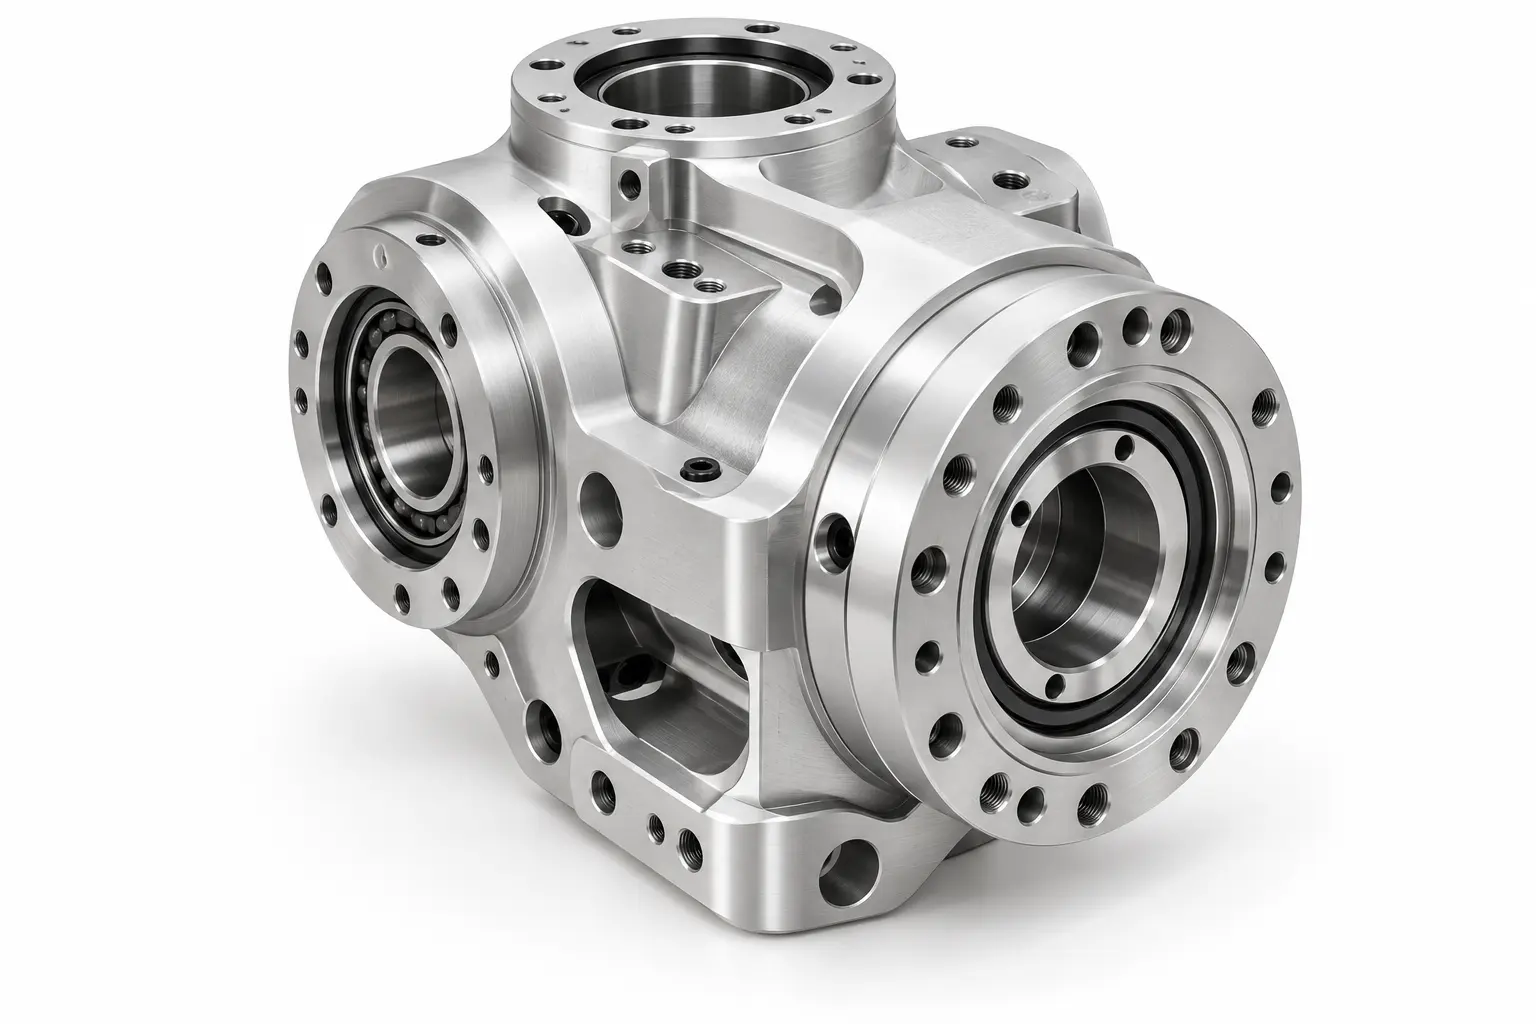
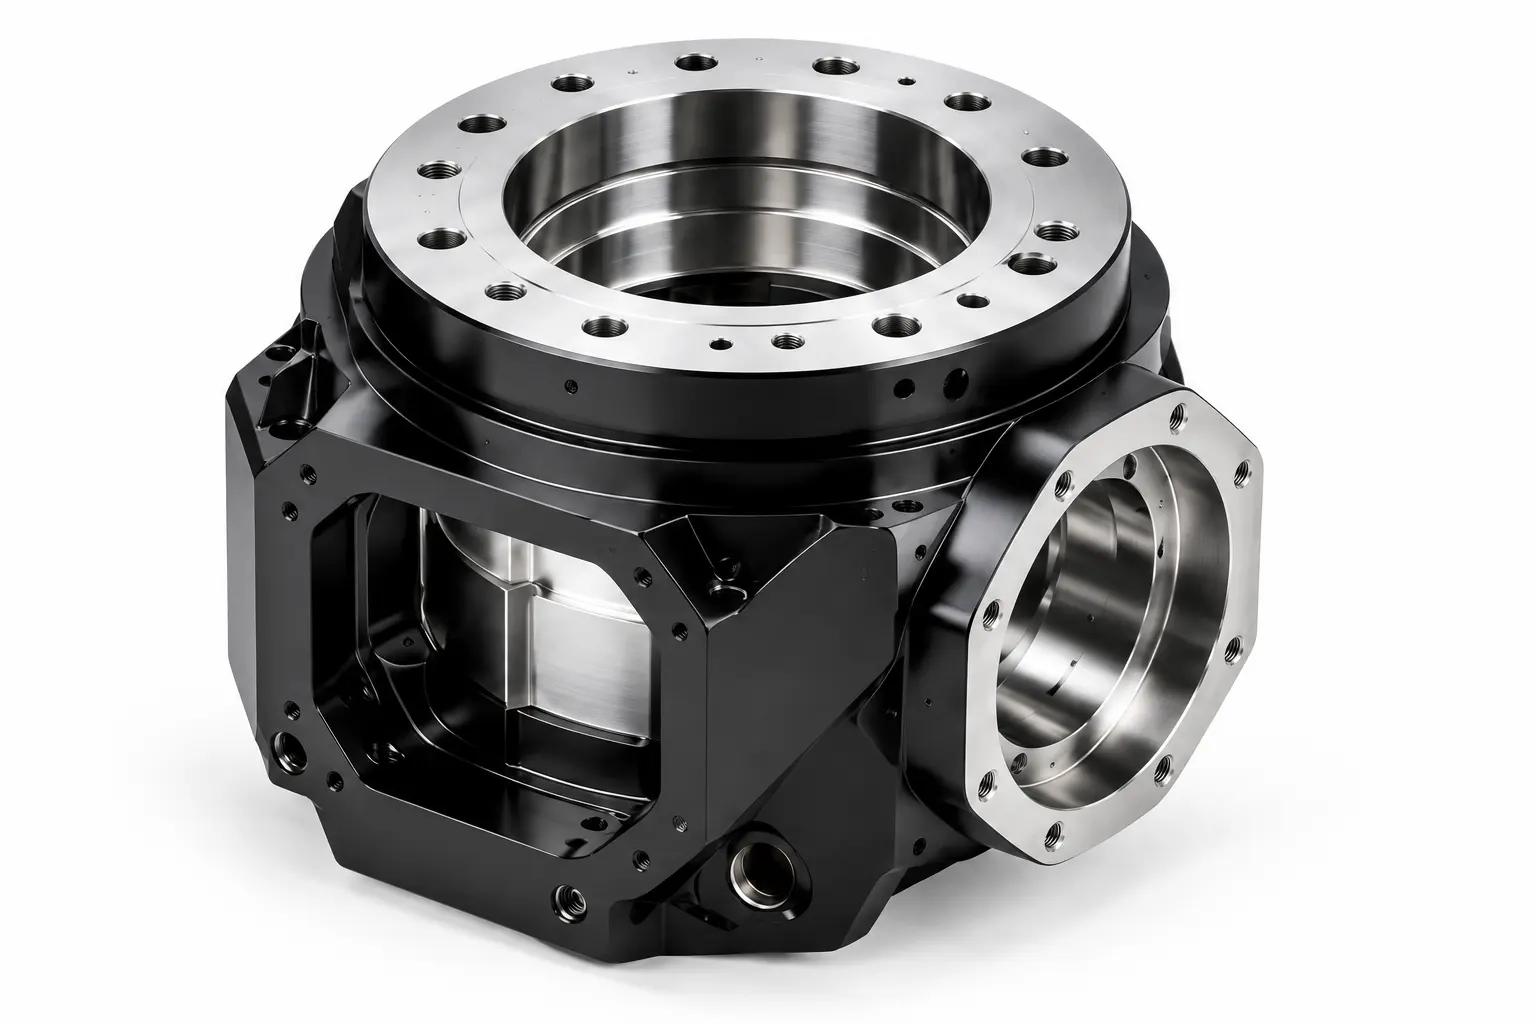
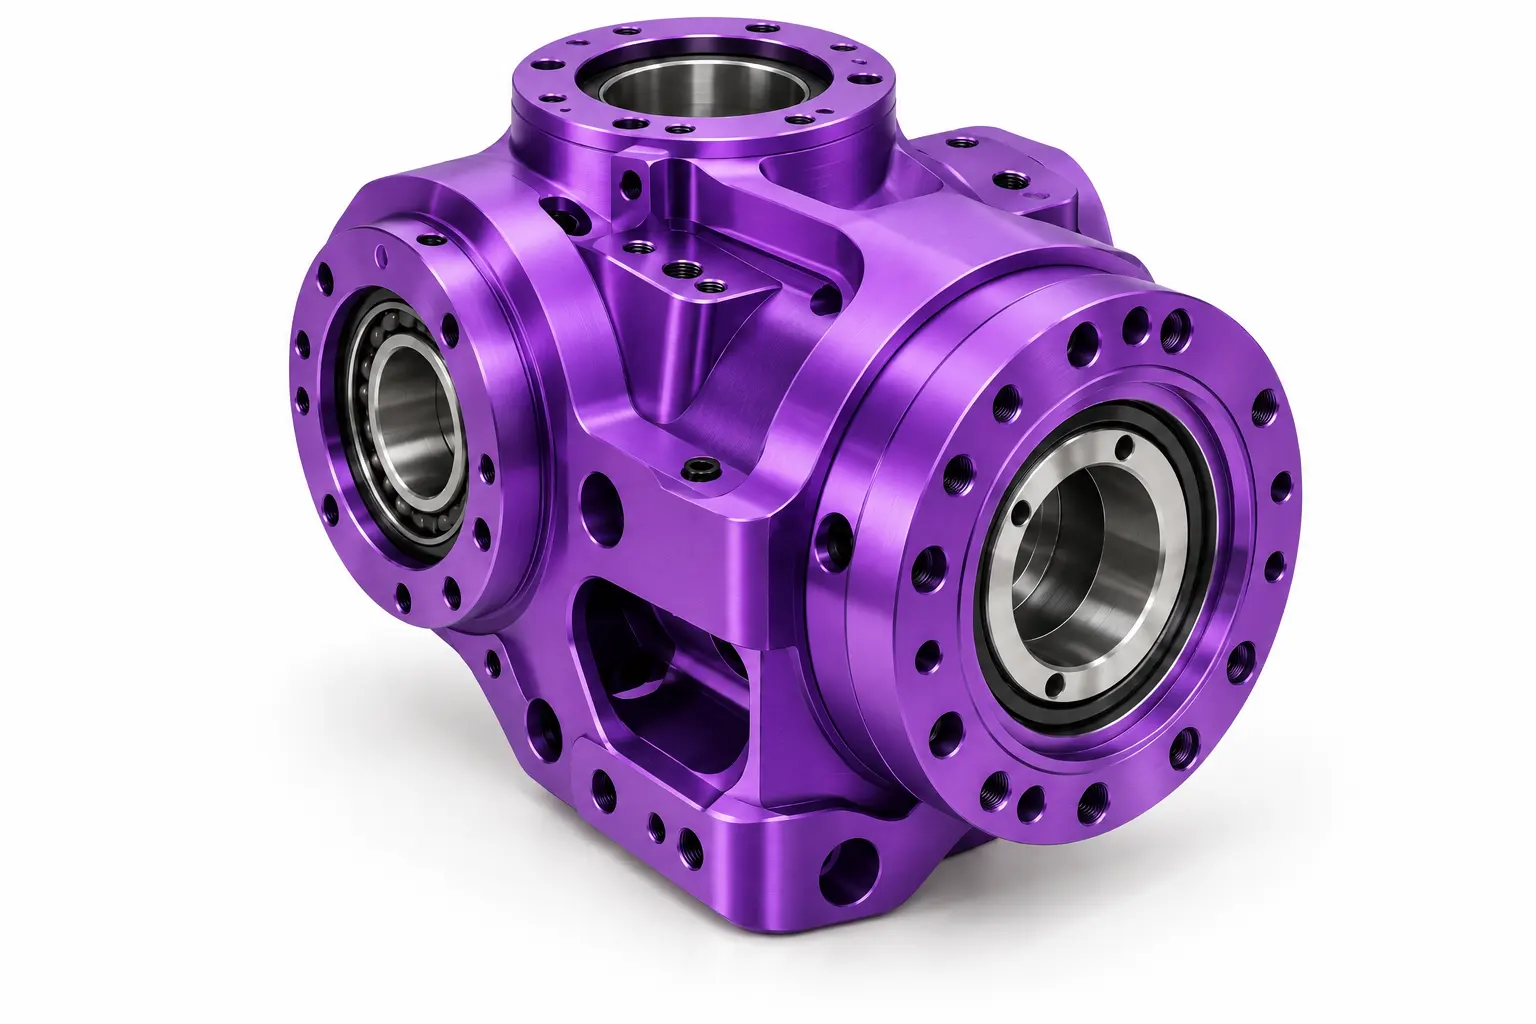
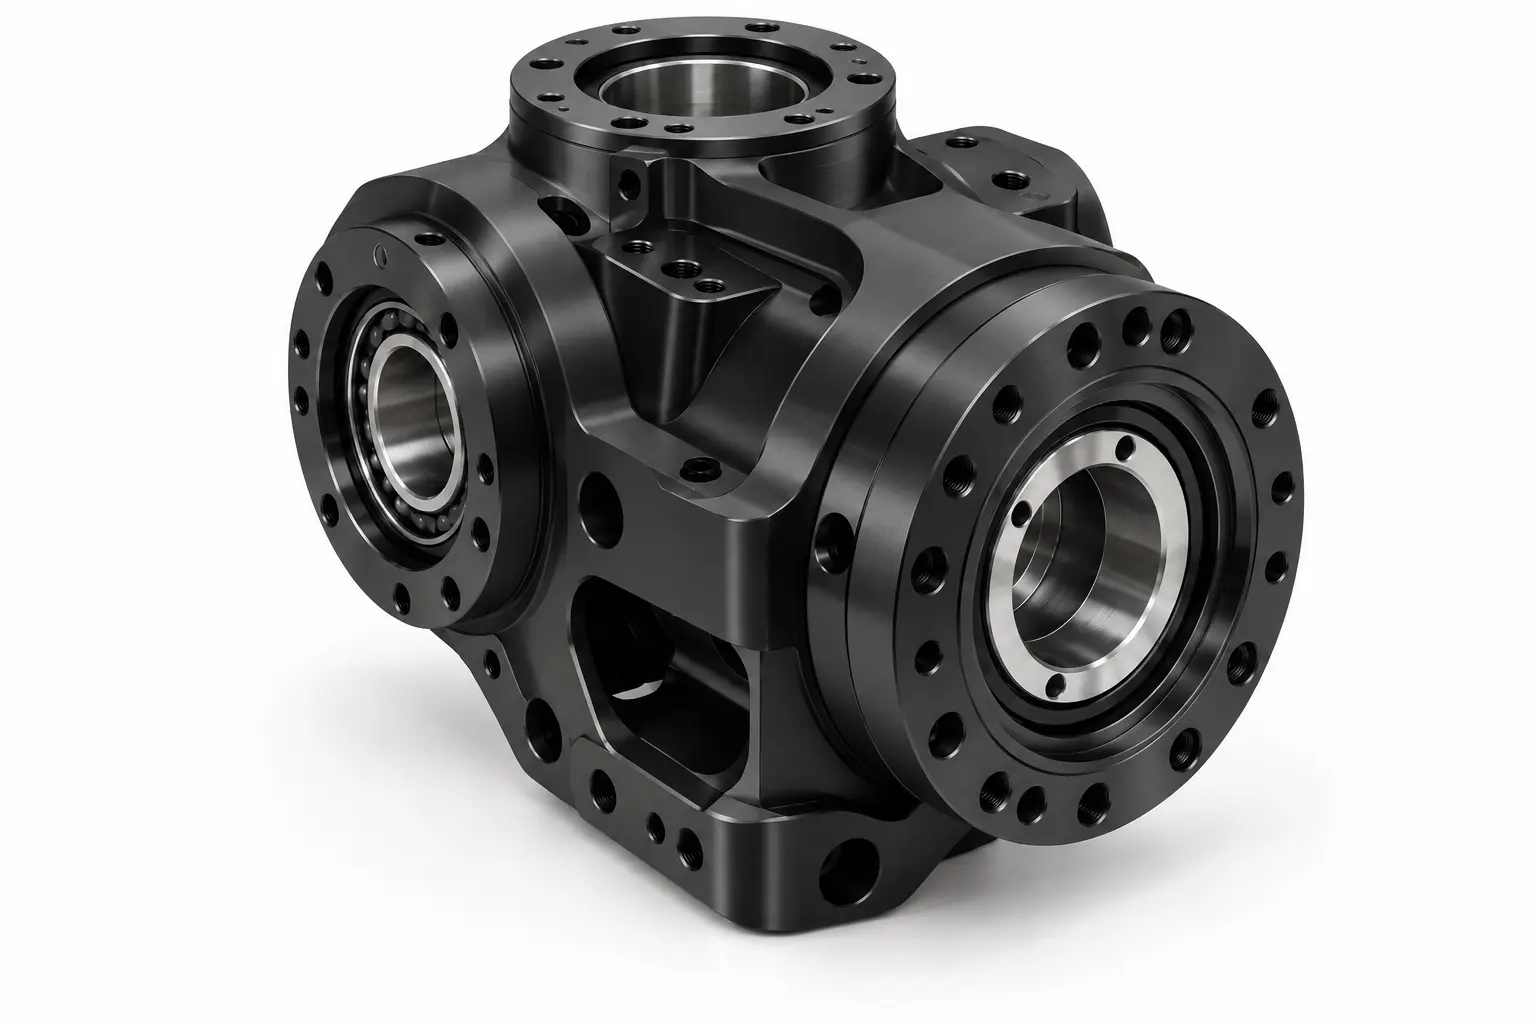
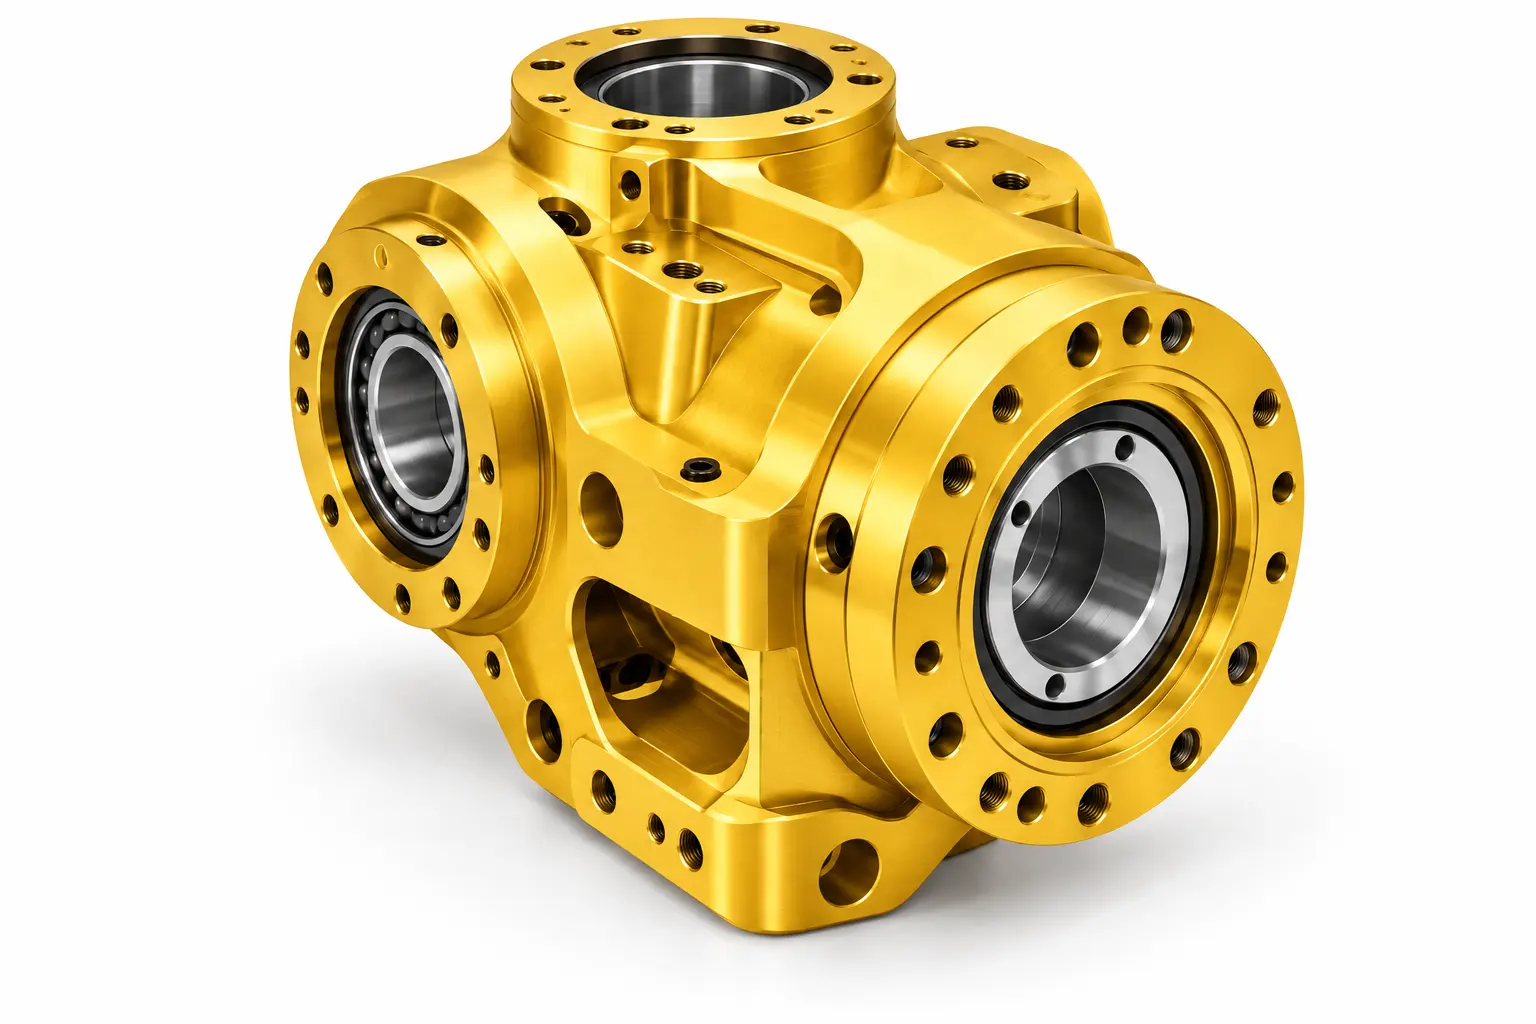
Robot Wrist Housing CNC Machining
Precision CNC machining for robot wrist housings with bearing seats, actuator interfaces, tool flanges, encoder mounts, cable passages, and compact multi-axis features. Supports 5-axis machining, tight GD&T, lightweight materials, and prototype-to-low-volume production.
- 5-Axis CNC for Compact Wrist Housings
- Precision Bearing & Axis Alignment
- Tool Flange & End-Effector Interfaces
- 6061 / 7075 Aluminum / Titanium
- Prototype & Low-Volume Production
Product Description
Introduction
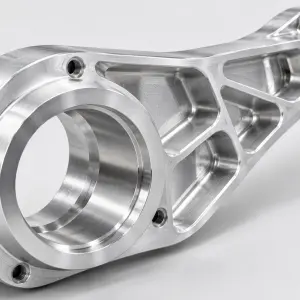
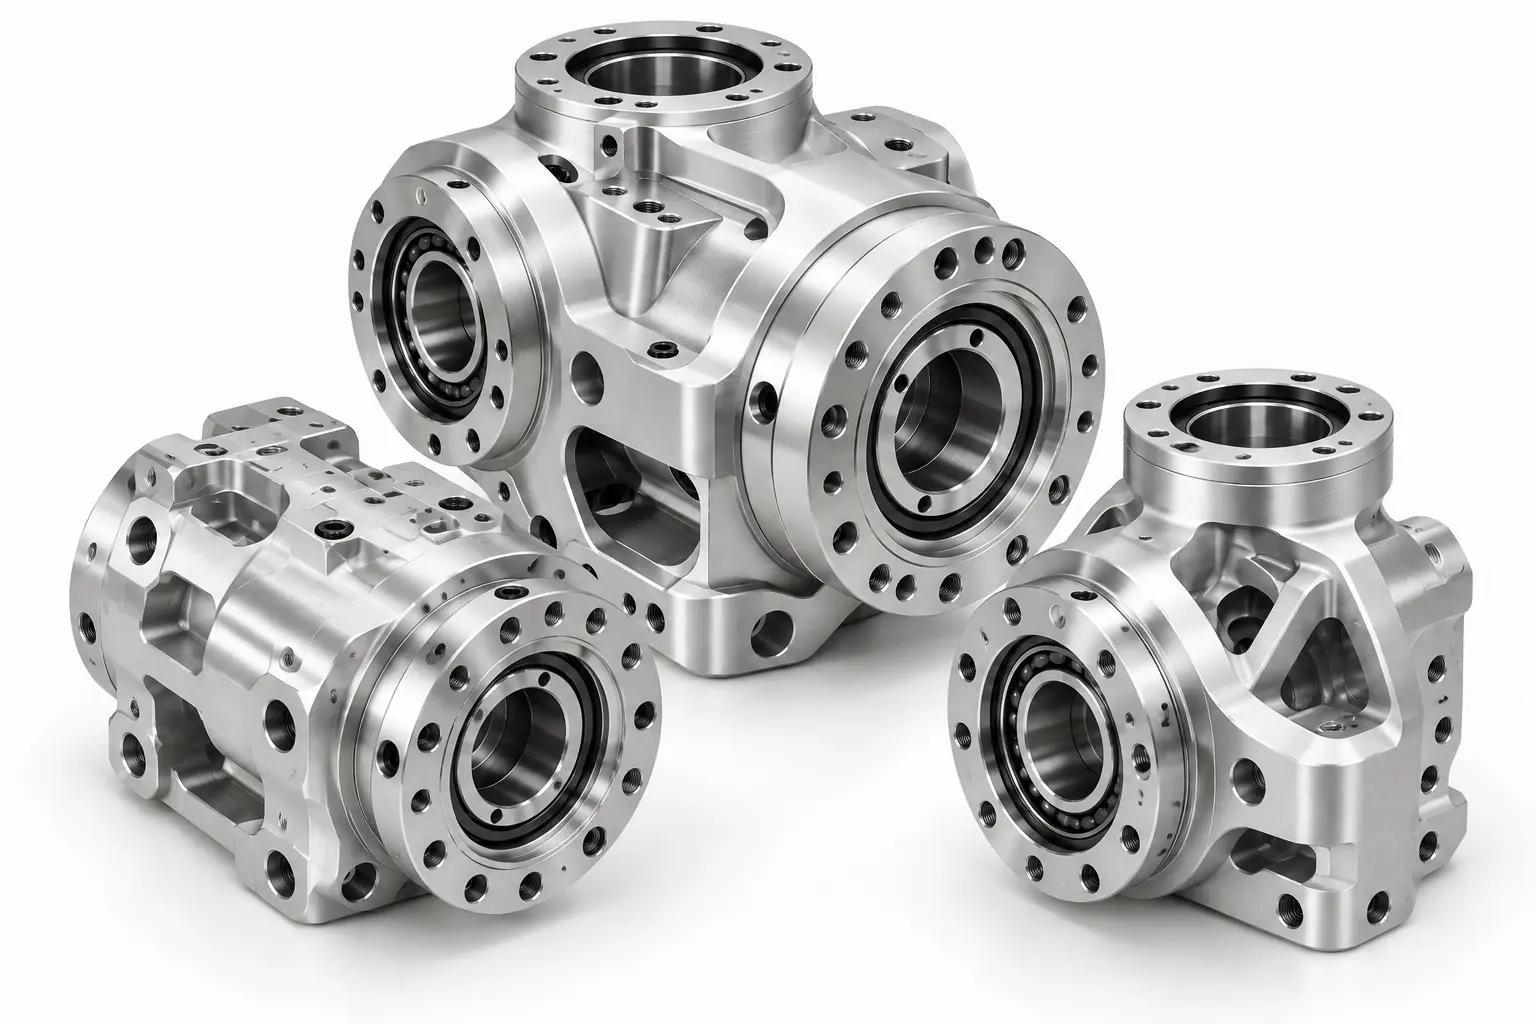
Robot Wrist Housing CNC Machining is used to manufacture compact structural housings that connect robotic arm links, actuators, bearings, sensors, and end-effector interfaces within multi-axis wrist assemblies. Accurate machining is critical for maintaining axis alignment, low rotational inertia, structural rigidity, and repeatable end-effector positioning.
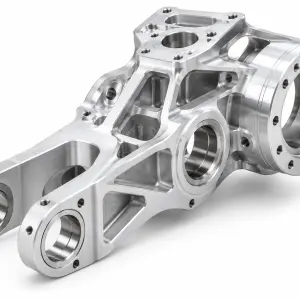
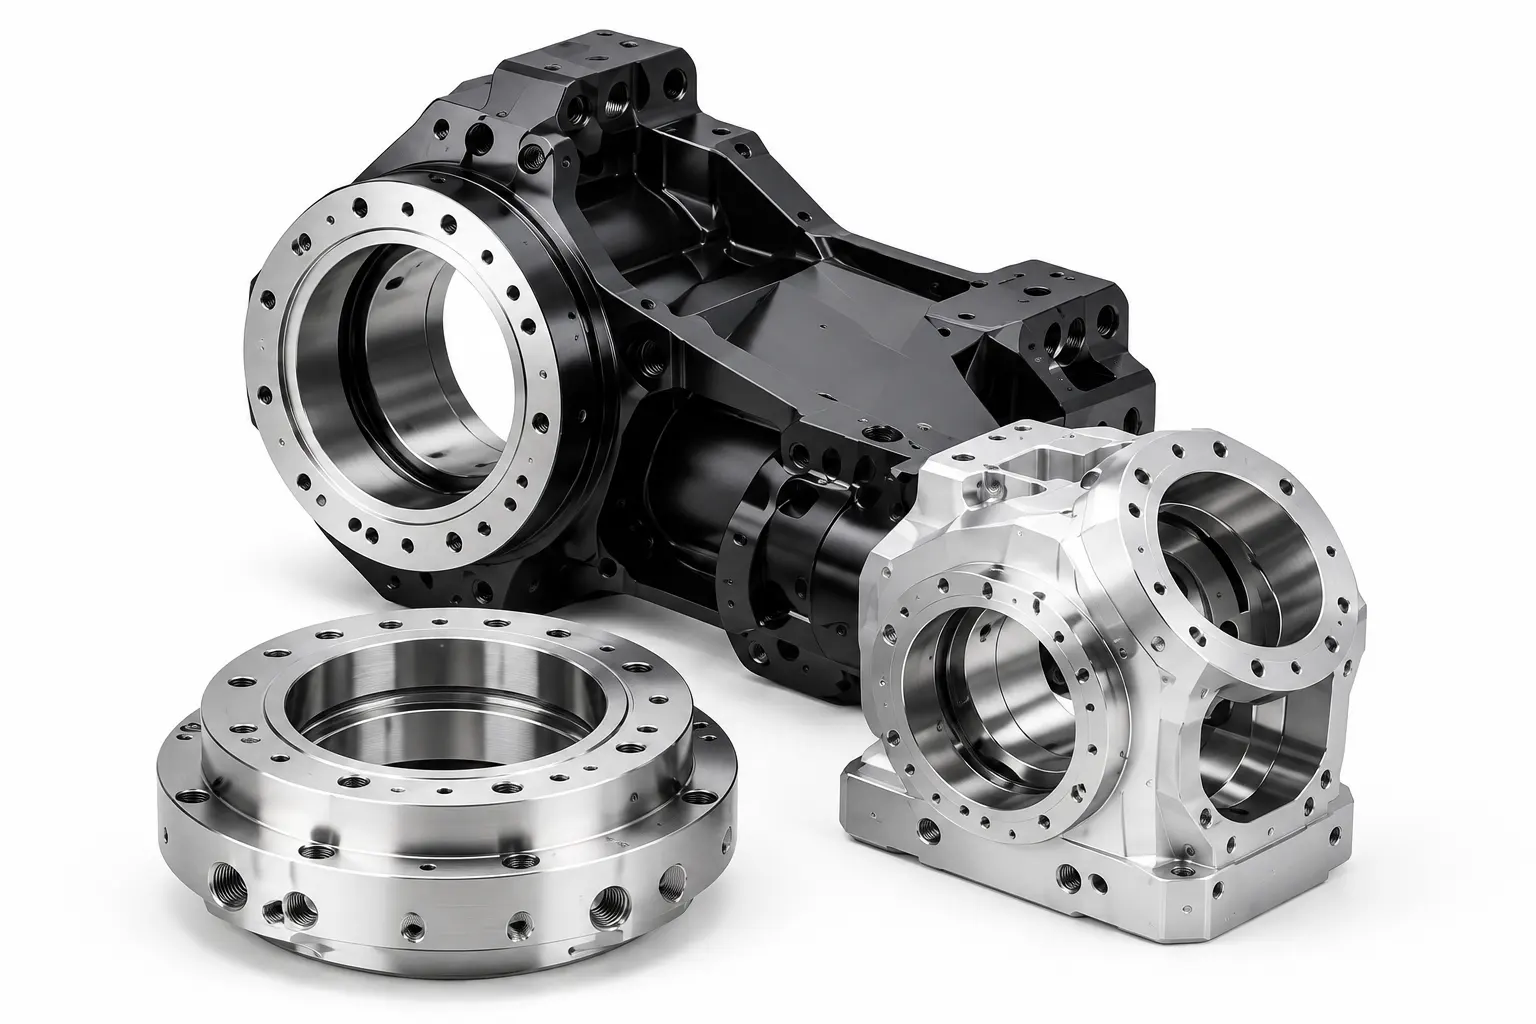
Robot wrist housings often contain precision bearing seats, concentric bores, actuator mounting interfaces, tool flanges, encoder or sensor mounts, cable passages, thin-wall sections, and multi-directional mounting features. Small deviations in bore position, concentricity, runout, flatness, or perpendicularity can affect wrist-axis alignment, bearing fit, vibration, assembly accuracy, and robotic motion performance.
Our CNC machining capabilities include 3-axis, 4-axis, and 5-axis milling, CNC turning, boring, drilling, threading, tapping, pocket machining, and precision finishing. Machining strategies, fixture design, datum control, tool access, and inspection methods are selected according to compact wrist geometry, critical bearing relationships, GD&T requirements, and assembly conditions.
Robot wrist housings can be machined from 6061 aluminum, 7075 aluminum, stainless steel, titanium, and other engineering materials, with anodizing, hard anodizing, passivation, polishing, plating, coating, and other secondary processes available. Prototype, engineering sample, and low-volume production can be supported according to customer drawings.
Specifications
| Item | Specification |
|---|---|
| Product Name | Robot Wrist Housing CNC Machining |
| Material | 6061 Aluminum / 7075 Aluminum / Stainless Steel / Titanium / Custom |
| Manufacturing Process | Milling / Turning / Boring / Drilling / Threading / Tapping / Precision Finishing |
| Part Geometry | Compact / Thin-Wall / Deep Cavity / Multi-Axis / Multi-Surface / Custom |
| Tolerance | Up to ±0.005 mm / According to Drawing |
| Surface Finish | Anodizing / Hard Anodizing / Passivation / Plating / Coating |
| Color | Natural / Black / Material-Dependent |
| Production Volume | Prototype and Low-Volume Production |
| Inspection | CMM / Height Gauge / Micrometer / Caliper / Custom Inspection Plan |
| Documentation | Inspection Reports and Material Documents Upon Request |
| Applications | Humanoid Robots / Collaborative Robots / Industrial Robots / Service Robots / Robotic End Effectors |
| Custom Service | OEM and ODM Supported |
Three Key Customization Aspects, Tailored to Your Needs
Customized CNC machining solutions for complex robotic components and precision assembly requirements.
Precision Manufacturing, Excellent Quality
Compact Multi-Axis Machining
5-axis machining supports angled bores, deep cavities, multi-side interfaces, cable-routing features, and compact geometries while reducing repeated setups.
Precision Bearing & Axis Alignment
Bearing seats, concentric bores, and actuator mounting features are carefully machined to maintain alignment between multiple wrist axes.
Tool Flange & End-Effector Interfaces
Tool mounting surfaces, bolt patterns, locating features, and end-effector interfaces can be machined with tight positional control to support repeatable robotic operation.
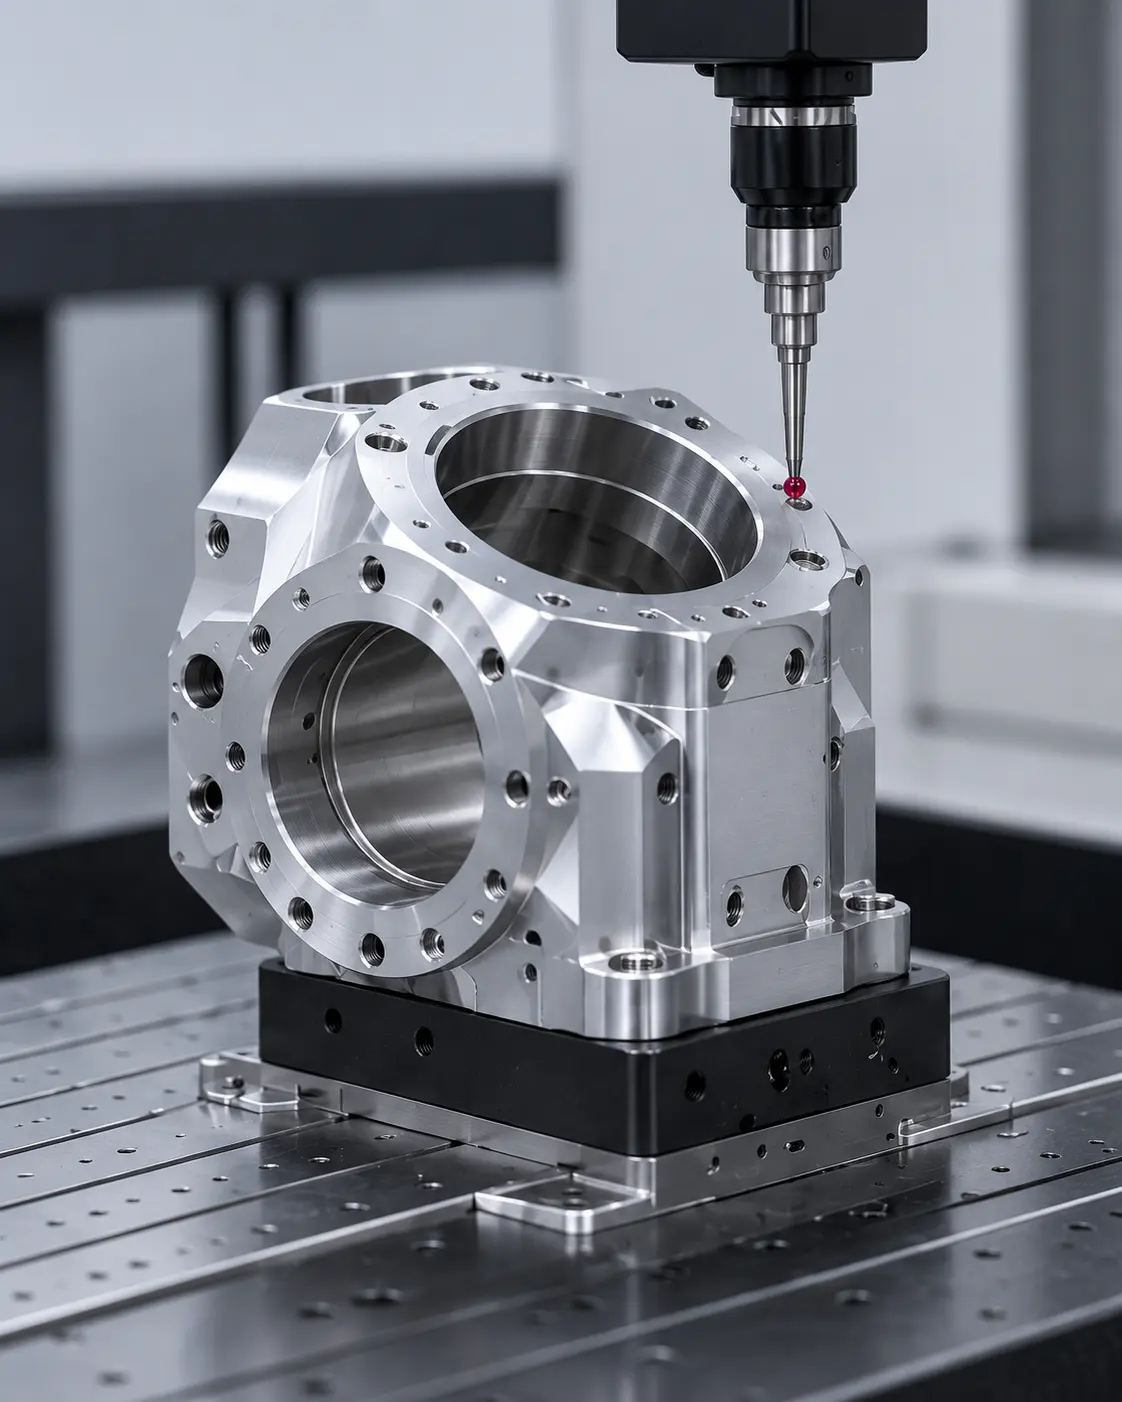
Multi-Surface Inspection
CMM, bore gauges, micrometers, and other inspection equipment can verify bore position, concentricity, runout, flatness, and critical interface relationships before assembly.
Refined Service, Shortened Delivery Time
From design review to delivery, we provide dedicated one-on-one follow-up throughout the entire process.
Consultation → Provide Drawings → Design Review & Quotation → Order Processing → Quality Inspection → On-time Delivery → After-sales Follow-up
Our Advantages
Backed by over 25 years of engineering experience, our team offers comprehensive services—from customized mold design and precision machining to full-scale production—supported by a robust quality assurance system and proactive customer service. Certified under ISO9001, ISO14001, and IATF 16949, we continually strive for excellence in quality, innovation, and customer satisfaction.
Over 100,000 units in stock, with 2-hour shipment for standard products.
Implementing a three-stage inspection system—initial material check, in-process inspection, and final inspection.
Large inventory and quick turnaround, ensuring on-time delivery with 100% product inspection.
Application Range
The preferred choice across various industries.
FAQ
Q1: What is a robot wrist housing? A robot wrist housing is the structural component that supports bearings, actuators, sensors, and tool interfaces in the final motion axes of a robotic arm.
Q2: Why is precision important in robot wrist housings?
The wrist contains several closely integrated motion interfaces. Errors in bearing position, bore alignment, or mounting surfaces can affect end-effector positioning, vibration, and motion repeatability.
Q3:What materials are commonly used for robot wrist housings?
6061 and 7075 aluminum are commonly used for lightweight robotic wrist structures, while stainless steel or titanium may be selected for higher strength, rigidity, or environmental requirements.
Q4: Is 5-axis CNC machining suitable for robot wrist housings?
Yes. Wrist housings often include multi-angle features, compact cavities, bearing bores, cable passages, and mounting surfaces located on several sides, making 5-axis machining particularly suitable.
Q5: How are robot wrist housings inspected?
Inspection can include CMM, bore gauges, micrometers, height gauges, and custom inspection fixtures to verify bearing seats, axis relationships, tool interfaces, and GD&T requirements.